What we built
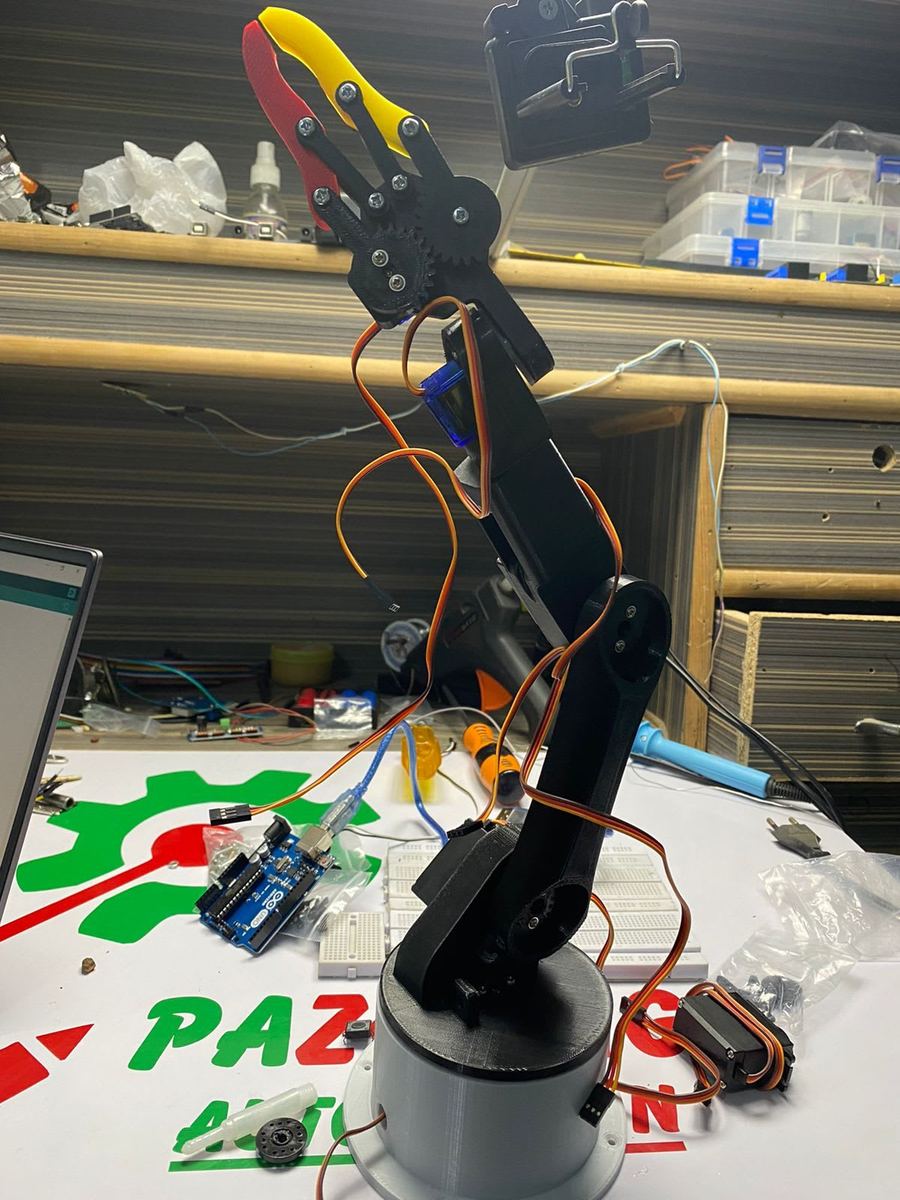
A multi-axis desktop robotic arm built from 3D-printed links and a rotating base, driven by metal-gear and micro servos. The geared gripper picks up small objects, and the Arduino firmware coordinates each joint for smooth, repeatable motion.
- Arduino
- Servos
- 3D printing
- Motion control